tools
openpi
Open-source robotics models and packages for running, fine-tuning, and serving vision-language-action policies.
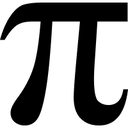
openpi provides open-source π₀, π₀-FAST, and π₀.₅ vision-language-action models for robotics. It includes base and fine-tuned checkpoints, inference examples, training scripts, PyTorch support, and a remote policy server.
Researchers and robotics developers can adapt the models to datasets and platforms such as DROID, ALOHA, and LIBERO. It is not a hosted service; users provide compatible hardware and software environments. The repository currently targets Ubuntu 22.04 with an NVIDIA GPU and does not support other operating systems.
Features
- Provides π₀, π₀-FAST, and π₀.₅ vision-language-action models
- Includes base checkpoints pretrained on 10k+ hours of robot data
- Supports inference and fine-tuning on custom datasets
- Offers JAX and PyTorch implementations
- Runs a policy server for local or remote robot inference
- Streams actions to robots over a websocket connection
- Includes examples for DROID, ALOHA, and LIBERO
- Licensed under Apache-2.0
Use cases
- Fine-tune a base VLA model on a custom robot dataset
- Run pretrained policies on DROID or ALOHA robots
- Serve inference from a more powerful off-robot GPU
- Evaluate robot policies with the LIBERO benchmark
- Convert JAX checkpoints to PyTorch format