Research
KASALv2: Fully Automatic 3D Rotational Symmetry Classification and Axis Localization
KASALv2: Fully Automatic 3D Rotational Symmetry Classification and Axis Localization Overview Research area: Computer vision / 3D geometry, specifically rotational symmetry analysis of 3D objects and
- arXiv
- 2610.09534
- Published
- 2026-10-07
- Authors
- Mengxin Zhang, Yulin Wang, Chen Luo, Yongzhe Li, Yijun Zhou
AI summary
KASALv2: Fully Automatic 3D Rotational Symmetry Classification and Axis LocalizationOverview
Research area: Computer vision / 3D geometry, specifically rotational symmetry analysis of 3D objects and its use as a prior for 6D pose estimation.
Technical level: Advanced. The method builds on group-theoretic descriptions of rotational symmetry (the orientation-preserving subgroups of SO(3), including C∞, D∞, Cn, Dn and the Platonic groups A4, S4, A5), plus non-convex optimization over the unit sphere and frequency analysis of self-alignment signals.
One-sentence scope: The paper presents a reference-free pipeline that, given only a 3D object, automatically determines its rotational symmetry type, its rotational order, and all of its canonical symmetry axes, and shows that these automatically derived priors improve downstream 6D pose estimation.
What This Paper Is About
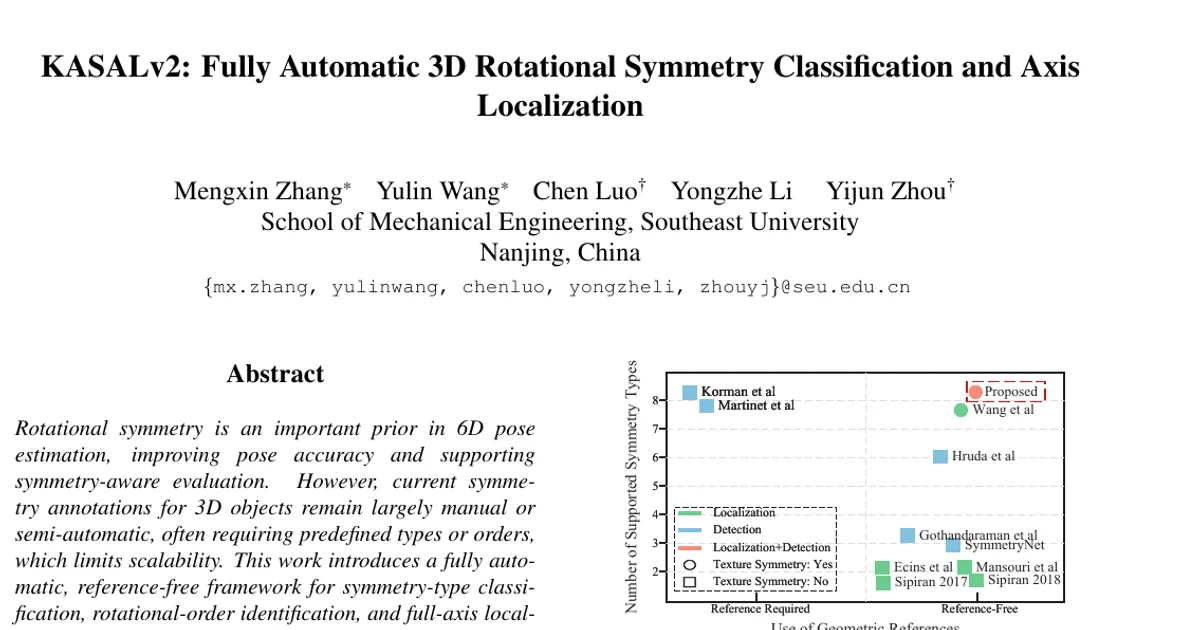
Knowing an object's rotational symmetry matters for 6D pose estimation, because a symmetric object has many physically identical poses that must be treated as equivalent during training and evaluation. Today, most 3D symmetry annotations are produced by hand or by semi-automatic tools that require the user to specify a symmetry type or an order in advance, which does not scale to datasets with tens of thousands of models. This paper's goal is to remove that human input entirely: from a raw 3D object with no reference frame, the method decides the symmetry type, identifies the rotational order, and localizes the complete set of symmetry axes across all eight canonical rotational symmetry types, including cases where surface texture reduces the apparent rotational order.
Key Contributions
-
A unified, fully automatic framework for 3D rotational symmetry analysis that performs symmetry-type classification, rotational-order identification, and full-axis localization across all eight canonical types in a reference-free pipeline (no centroids, keypoints, templates, or predefined types or orders).
-
The Geometric Degeneration Hierarchy (GDH), a computable, geometry-driven hierarchy that reorganizes the SO(3) rotational symmetry families through structured axis reduction (for example D∞ ⇒ Dn, C∞ ⇒ Cn, D∞ ⇒ C∞, Dn ⇒ Cn, and A5 ⇒ A4, S4 ⇒ A4), supplying the algorithmic pathway that maps an unknown object to its canonical symmetry family.
-
An operational instantiation of the GDH that determines the type consistently, localizes a dominant high-order axis stably, and includes a texture-aware extension modeling appearance-induced reductions in rotational order while preserving axis orientations.
-
A scalable, annotation-free source of rotational symmetry priors for unseen-object pose estimation: training FoundationPose with these priors on a one-million-image corpus yields up to a 0.9% gain on BOP.
Main Findings
-
Strong accuracy on scanned real-world objects in GSO: the method reaches 94.75% overall correctness on 438 symmetric objects out of 944 scanned models in GSO, with e_ADI/d = 0.00262 and 1.37 s average runtime per object.
-
Effective on the manually designed DSRSTO benchmark: 81.48% overall accuracy with e_ADI/d = 0.00212 and 1.46 s runtime across 38 CAD objects (27 geometrically symmetric, 11 texture-symmetric). Errors concentrate in the Cn category, which drops to 28.57% in category statistics.
-
Improvement on BOP under stricter re-annotation: on 50 symmetric instances, accuracy rises to 84.00% compared with 80.00% under the original labels, with e_ADI/d reduced from 0.00290 to 0.00256.
-
Texture-induced symmetries are handled: on the DSRSTO texture subset the method achieves 72.32% accuracy with e_ADI/d = 0.00195 and 1.16 s runtime, showing it remains usable when appearance breaks geometric rotational invariance.
-
Cn is consistently the hardest category: the lower DSRSTO performance is attributed mainly to challenging high-order and visually ambiguous Cn cases, and Cn is also the lowest-accuracy category on BOP.
-
Automatic priors improve downstream pose estimation: two identically configured FoundationPose models trained on about one million rendered GSO images, differing only in the use of KASALv2-derived rotational-symmetry priors
Authors’ abstract
Rotational symmetry is an important prior in 6D pose estimation, improving pose accuracy and supporting symmetry-aware evaluation. However, current symmetry annotations for 3D objects remain largely manual or semi-automatic, often requiring predefined types or orders, which limits scalability. This work introduces a fully automatic, reference-free framework for symmetry-type classification, rotational-order identification, and full-axis localization across all eight canonical 3D rotational symmetry types. The method localizes a dominant high-order axis, infers its rotational order through self-consistency analysis, and reconstructs the complete symmetry structure under a hierarchy-guided formulation. A texture-aware extension further models appearance-induced reductions in rotational order while preserving axis orientations. Experiments on idealized and real-world datasets demonstrate strong accuracy and generalization, achieving 94.75% accuracy on 438 symmetric objects in GSO. Training FoundationPose with these priors improves accuracy by up to 0.9% across five BOP datasets, showing that automatically estimated rotational priors improve downstream 6D pose estimation. Code is available at https://github.com/WangYuLin-SEU/KASAL.