Research
EB-MBD: Emerging-Barrier Model-Based Diffusion for Safe Trajectory Optimization in Highly Constrained Environments
Overview Research area: Robotics — constrained trajectory optimization, sampling-based motion planning, and diffusion-based optimization. Technical level: Intermediate to Advanced. The paper assumes f
- arXiv
- 2510.07700
- Published
- 2025-10-09
- Authors
- Raghav Mishra, Ian R. Manchester
AI summary
Overview
Research area: Robotics — constrained trajectory optimization, sampling-based motion planning, and diffusion-based optimization.
Technical level: Intermediate to Advanced. The paper assumes familiarity with diffusion models (DDPM), Stein score estimation, and constrained optimization concepts such as interior point methods and log barriers.
Scope: The paper introduces Emerging-Barrier Model-Based Diffusion (EB-MBD), a modification to Model-Based Diffusion (MBD) that replaces hard indicator-function constraints with a progressively tightening log-barrier, and evaluates it on a 2D obstacle avoidance problem and a 3D underwater vehicle manipulator system.
The paper is authored by Raghav Mishra and Ian R. Manchester of the Australian Robotic Inspection and Asset Management (ARIAM) Hub, the Australian Centre for Robotics, and the School of Aerospace, Mechanical and Mechatronic Engineering at the University of Sydney, and is funded by the Australian Research Council through the ARC Research Hub in Intelligent Robotic Systems for Real-Time Asset Management (IH210100030). It appears as arXiv:2510.07700v2 [cs.RO].
What This Paper Is About
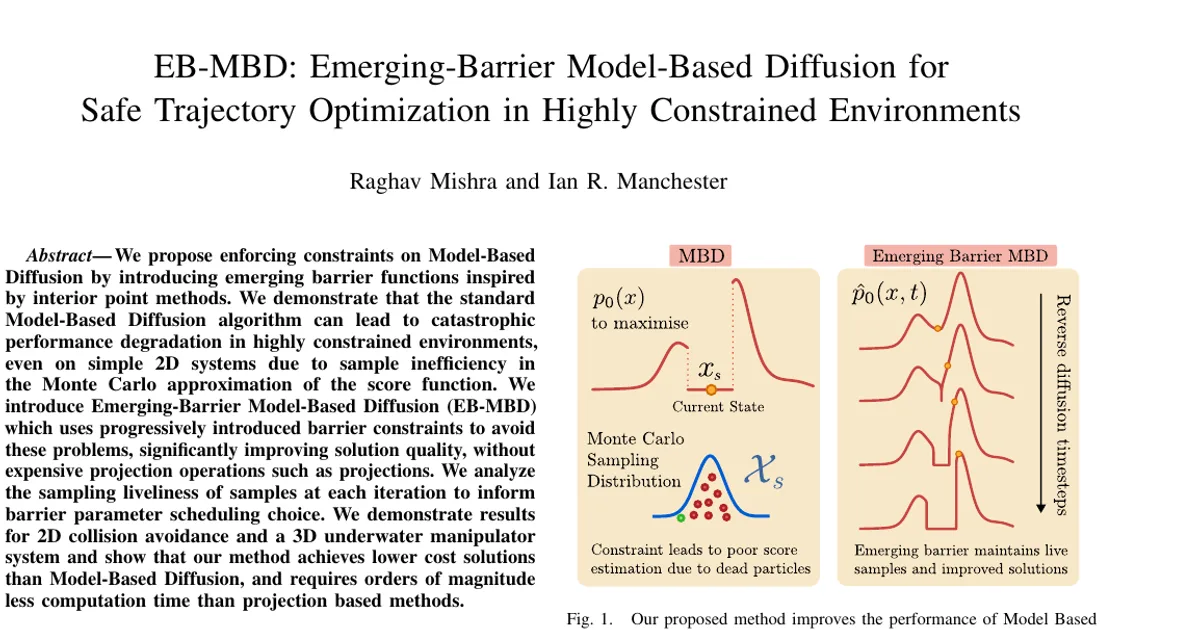
Model-Based Diffusion (MBD) solves optimization problems by running a learning-free reverse diffusion process, using Monte Carlo samples to approximate the Stein score. When constraints such as collision avoidance rule out most of the solution space, the samples that land in infeasible regions contribute nothing to the score estimate, producing "dead" samples and causing the algorithm to fail catastrophically — even on simple 2D systems.
The paper's goal is to make MBD work in highly constrained environments without resorting to expensive projections, by borrowing the log-barrier idea from interior point methods and introducing the constraint gradually over the diffusion process instead of imposing it all at once.
Key Contributions
-
Demonstrating MBD's failure mode. The authors show that MBD can suffer catastrophic performance degradation in highly constrained state spaces because the Monte Carlo score estimate is dominated by rare events when infeasible regions cover much of the solution space. This is illustrated by increasing the obstacle radius in a 2D obstacle avoidance problem until MBD fails.
-
Proposing Emerging-Barrier MBD (EB-MBD). The method augments MBD's target distribution with a time-varying log-barrier that includes a positive offset, so the constraint relaxes early in the reverse process and tightens toward the true feasible set at the end, guaranteeing feasibility in the limit without any projection operations.
-
Analyzing sampling statistics and barrier hyperparameters. The paper derives a lower bound on the probability of drawing a live (feasible) sample at each iteration, relating it to the barrier softness, the barrier offset schedule, the sampling variance, and the Lipschitz constant of the cost, and uses this to reason about the trade-offs in scheduling.
-
Benchmarking against projection-based constrained diffusion. EB-MBD is compared to MBD, a projection-based MBD variant, and a DPCC-style tightening-constraint method on the 2D task, and to MBD on the 3D underwater manipulator, showing lower costs at a fraction of the computational cost.
Main Findings
-
MBD collapses under tight constraints. Increasing obstacle size in a 2D obstacle avoidance problem causes catastrophic degradation in MBD performance, which the authors attribute to poor sampling efficiency in the score estimate.
-
EB-MBD reaches the goal where MBD does not. In the 2D task, every EB-MBD trajectory reaches near the target while maintaining diverse solutions, whereas none of the MBD solutions reach the target; many MBD trajectories violate constraints throughout the process.
-
Quantitative 2D comparison (50 trajectories). EB-MBD achieves mean cost 234.7 and mean final distance 0.2285 with runtime 0.0383 s. MBD gets mean cost 514.6, mean final distance 4.3590, runtime 0.0382 s. Projected MBD gets 533.2, 4.8517, 49.6752 s. DPCC-MBD gets 479.5, 3.8221, 7.3621 s. EB-MBD thus produces substantially lower cost and terminal distance at orders-of-magnitude lower runtime than the projection methods.
-
Quantitative underwater manipulator comparison (50 trajectories). On the UVMS, EB-MBD achieves mean cost 362.94 and a 48% success rate with 53 s runtime, compared to MBD's mean cost 427.25, 22% success rate, and 50 s runtime. The authors define success as the percentage of time the end effector was inside the box without collision.
-
Barrier scheduling matters and has coupled failure modes. With a power-law offset schedule, low κ produces poor local minima similar to MBD. Increasing κ generally improves performance, but if the tightening constraint boundary overshoots the current iterate, the diffusion process can die permanently — κ > 1 is shown to lead to 100% constraint violations and infeasible outputs. Raising μ increases the "boundary layer" distance and can counteract this.
-
Projection methods do not transfer well to MBD. Enforcing feasibility by projecting each iterate onto the constraint set is insufficient for MBD because sampling statistics around the projected iterate are still poor early in the process, when variance is high.
-
Scalability claim. The authors state they were unable to run projection methods on the UVMS in a reasonable amount of computational time, whereas EB-MBD's compute only grows with extra evaluations of the constraint function g(x), rather than with the complexity of a nonlinear program.
Methodology in Plain English
MBD turns an optimization problem into a sampling problem: it builds a Boltzmann-Gibbs distribution whose density is high where cost is low, then runs a reverse diffusion process toward it. Because no neural network is trained, each reverse step estimates the score by drawing a cloud of candidate points around the current iterate and taking a weighted average, where the weight is the target density. If almost every candidate is infeasible, the weights are all zero and the estimate carries no information.
EB-MBD fixes this by softening the constraint at the start. Instead of a hard "zero probability if infeasible" rule, it adds a logarithmic barrier term to the cost so the density stays positive everywhere, and then progressively tightens the barrier offset toward zero as diffusion proceeds. Early on, the constraint is loose and the search behaves like an unconstrained, exploratory global search; later on, the constraint tightens and the process behaves like local refinement, where the barrier acts as a repulsive force pushing iterates away from the constraint boundary while the original cost pulls them toward low-cost regions.
The offset schedule is parameterized as a power law decaying from a maximum value, and the barrier weight (softness) is controlled by a separate parameter held fixed across the experiments. The authors derive a lower bound on the probability that a sampled point is feasible, expressed through the Gaussian CDF, first assuming a general constraint and then under the additional assumptions that the iterate sits at the local minimum of the barrier-augmented cost and that the cost gradient is Lipschitz. This bound shows that softer barriers give lower-cost but less reliable samples, and that slow emergence rates compensate for softness. In hardware terms, the experiments were run with JAX on a PC with an i7-13700K, an RTX 3070 GPU, and 32 GB of memory, using MuJoCo MJX as the simulator oracle and SciPy's SLSQP solver with JAX autodifferentiation for the projection baselines. Code is released at https://github.com/acfr/emerging_barrier_mbd.
Why This Matters
Impact on research. The paper identifies a concrete failure mode of learning-free, sampling-based diffusion optimization — the collapse of the Monte Carlo score estimate when the feasible set is small — and offers a principled, projection-free remedy borrowed from interior point methods. It bridges classical constrained optimization theory with modern diffusion-based sampling and provides an analytical handle (the liveness lower bound) for tuning such methods.
Real-world applications:
- Underwater inspection and maintenance, where a vehicle-manipulator system must reach a target enclosed in a structure without colliding with it.
- Industrial asset inspection and management, the stated focus of the funding hub behind the work.
- General robot motion planning in cluttered workspaces where collision-avoidance constraints dominate the configuration space.
- Contact-rich or non-differentiable robotic tasks, since the method needs no gradients of the dynamics or constraint and only queries them as black boxes.
Industry relevance. The method runs on GPUs with parallel rollouts, has essentially constant solve time per inference (unlike NLP-based projections whose runtime varies with optimizer convergence and initial guess), and requires no retraining or data collection. That combination makes it attractive for deployment in settings where planning budgets are fixed and the environment changes frequently.
Future Directions
- Adaptive barrier schedules. The authors propose developing schedules that prevent permanently dead samples without requiring per-problem tuning of the barrier parameters.
- Relaxing the analysis assumptions. The current liveness bound relies on a local linearization of the constraint, a Lipschitz cost gradient, bounded minima, and a timescale separation between diffusion convergence and barrier emergence; the authors suggest analyzing EB-MBD under milder assumptions.
- Scaling the baseline comparison. Since projection methods could not be run on the underwater manipulator within a reasonable computational time, a fuller comparison on high-dimensional systems remains open.
- Robustness of feasibility guarantees. EB-MBD can return entirely infeasible solutions if the schedule is poorly chosen, so extending or strengthening guarantees of feasibility is an open question.
Target Audience
This paper is best suited to robotics researchers and graduate students working on motion planning and trajectory optimization, particularly those already familiar with sampling-based optimal control (MPPI, STOMP, CEM) or with diffusion-based planning. It also speaks to practitioners applying constrained optimization to high-dimensional robotic systems, and to optimization researchers interested in importing interior point ideas into sampling-based generative methods. Readers without a background in diffusion models or constrained optimization will find the analytical sections (barrier liveness bound, theorem and corollary) difficult, though the experimental comparisons are accessible on their own.
Authors’ abstract
We propose enforcing constraints on Model-Based Diffusion by introducing emerging barrier functions inspired by interior point methods. We demonstrate that the standard Model-Based Diffusion algorithm can lead to catastrophic performance degradation in highly constrained environments, even on simple 2D systems due to sample inefficiency in the Monte Carlo approximation of the score function. We introduce Emerging-Barrier Model-Based Diffusion (EB-MBD) which uses progressively introduced barrier constraints to avoid these problems, significantly improving solution quality, without expensive projection operations such as projections. We analyze the sampling liveliness of samples at each iteration to inform barrier parameter scheduling choice. We demonstrate results for 2D collision avoidance and a 3D underwater manipulator system and show that our method achieves lower cost solutions than Model-Based Diffusion, and requires orders of magnitude less computation time than projection based methods.